≈ Vector Index
Find the nearest, open the least.
A vector collection lives under a secret scope, stored in encrypted chunks. Search cost is how many chunks must be opened.
Kernel: this.me 4.2.1 (npm) ⓘ
Theory: Digital Space Algebra. This page is language-neutral; the implementation is linked at the end.
Exact and IVF
| Opens | Answer | |
|---|---|---|
exact searchExact |
every chunk | the true top k, by definition |
IVF searchVector |
the chunks near the nprobe closest centroids |
the true top k only if the neighbours sit in those chunks |
buildVectorIndex trains k centroids over chunk representatives and writes a sidecar index outside the kernel log. A query compares itself to the centroids first (cheap), then scans only the chosen chunks.
cost(exact) = all chunks        cost(IVF) ≈ nprobe chunks
recall@k = |IVF top k ∩ exact top k| / k
A small run
1,024 vectors of 256 dimensions in 4 clustered chunks, under a secret scope, on a disk store:
const me = new ME("vx", { store: new ME.DiskStore({ baseDir: "/tmp/vx" }) });
me.memory.episodic["_"]("k");
// 4 batches of 256 × 256-d vectors via the batch writer the kernel tests use (me._commitIndexedBatch)

me.searchExact("memory.episodic", q, { k: 3 });
// { hits: [600, 659, 541], scannedChunks: 4, scannedVectors: 1024 }

me.buildVectorIndex("memory.episodic", { k: 4, nprobe: 1 });
// { k: 4, nprobe: 1, totalVectors: 1024, totalChunks: 4 }

me.searchVector("memory.episodic", q, { k: 3, nprobe: 1 });
// { hits: [600, 659, 541], candidateChunks: 1, scannedVectors: 256 }
Run on Node with npm this.me 4.2.1 (the three methods are exported on ME); outputs are the real ones. Same top 3, a quarter of the vectors opened.
Layout decides
On a Mac with 100k vectors (this.me 4.2.1, nprobe 3):
| Layout | Recall@10 | Speedup vs exact (p95) |
|---|---|---|
| chunk-coherent | 1.000 | 62× |
| fragmented | 0.133 | 40× |
When similar vectors share chunks, IVF returns exactly the exact answer, 62× faster. When they are scattered, it is still fast but misses most of the right answers. Full numbers: Kernel benchmarks, Phase 3.
Status by implementation
| Exact search | IVF index | |
|---|---|---|
| TypeScript this.me 4.2.1 | implemented, tested, exported | implemented, tested, exported |
| Rust rust-v0.3.3 | none | none |
| Python | none | none |
Implementations
 TypeScriptME API: vector methodssearchExact, buildVectorIndex, searchVector and their options.
 TypeScriptPhasesPhase 3.0 exact search and 3.1 IVF: the tests behind this page.
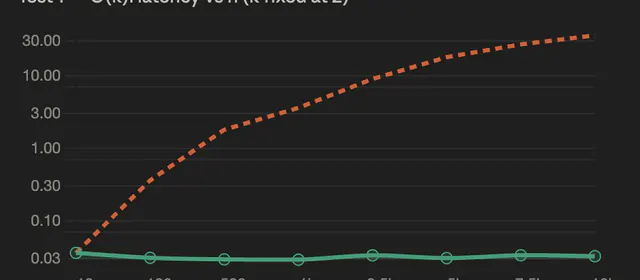 TypeScriptKernel benchmarksPhase 3 on a Mac: coherent vs fragmented layouts.
Rust and Python: no implementation yet.
See also
- Algebra of Contexts: Spaces inside spaces: path, predicate, plural and audience as one space (T, A, C, P).
- What is O(k)?: n is every value, k is what one write recomputes. The work follows k, read from explain(path).meta.
- Digital Space Algebra: The theory: topology, audience and capability as three sets over one space.
- mlearning.studio: Datasets and benchmark results (GTFS, BigDaMa).